03VISION-GUIDED SORTING / PROOF OF CONCEPT
PERSONAL PROJECT
VISION → DECISION → MOTION
See. Sort. Move.
A camera and YOLO vision pipeline identify objects. Jetson Nano and ROS connect the classification result to the robotic arm.
The controller maps each class to a sorting bin and prepares calibrated pick-and-place motions. End-to-end movement still depends on validation with the physical arm.
ROBOTIC ARM / HARDWARE REFERENCEYAHBOOM / DOFBOT
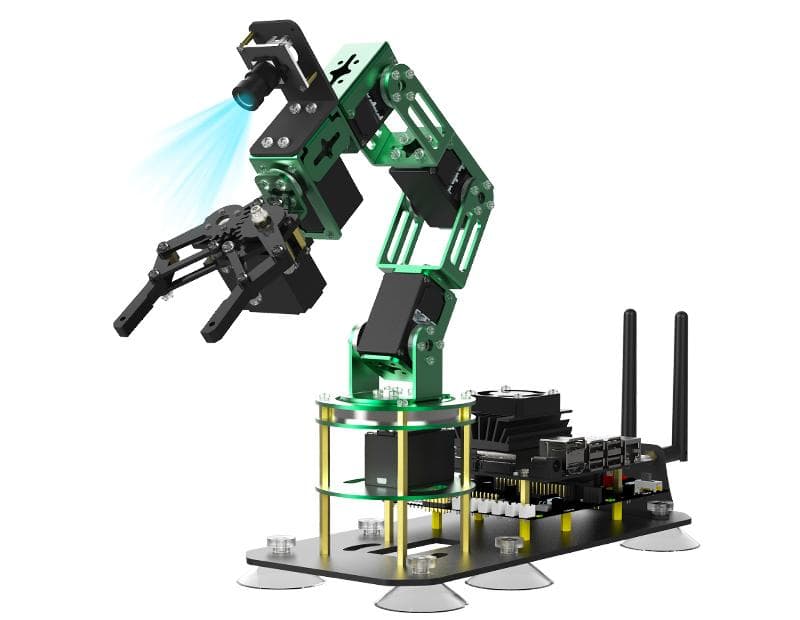 VISION + GRIPPER
SEE→CLASSIFY→DECIDE→MOVE→SORT