I led our team through a robotics challenge.
As UCAO-TECH team lead for TRC 2025, I coordinated our work across electronics, software and mechanics. Together, we documented the preselection tests and built an intelligent sorting conveyor.
Our website presents the wider EcoCity mission: collecting and sorting waste with robotics. I share our published work here, with links to the repository and project site.
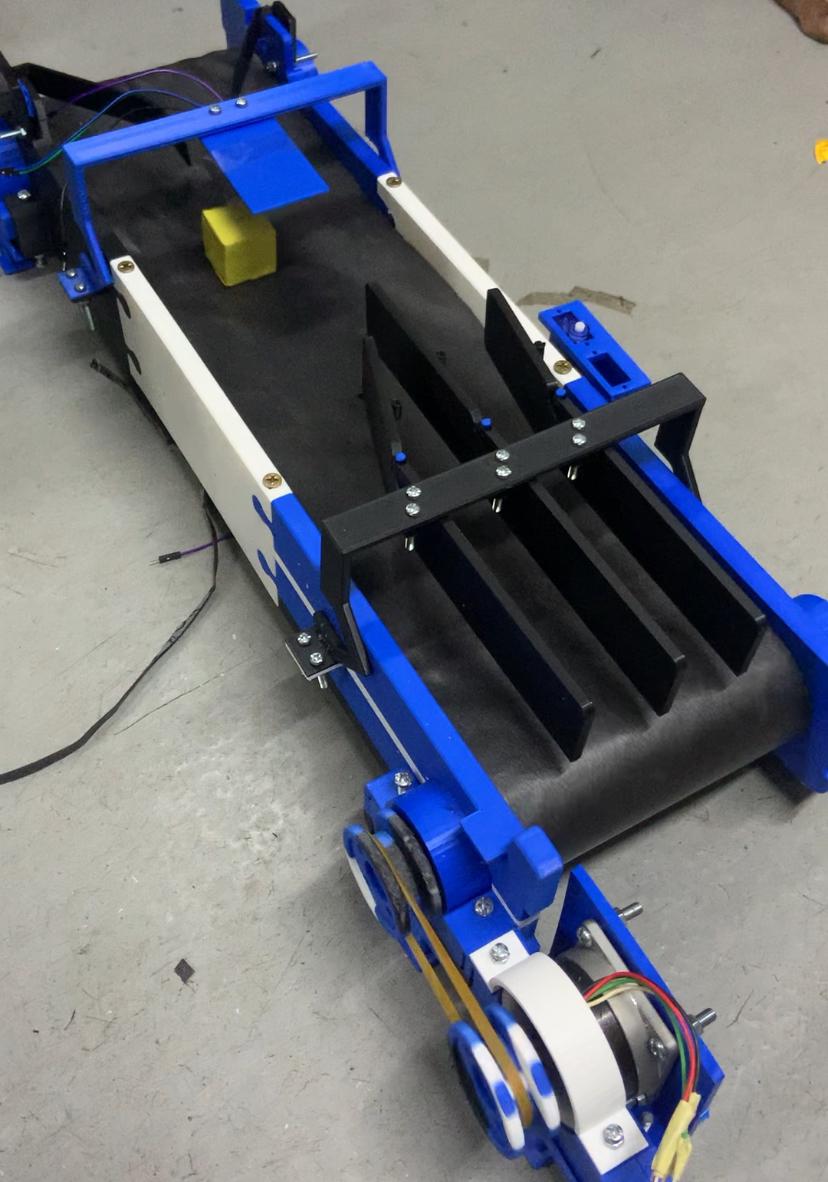
A real conveyor, not just a diagram.
In our repository, we brought together the mechanical build, embedded electronics and software work behind the sorting conveyor.
Image: UCAO-TECH team documentationElectronics
We worked through gyroscope, black box and seven-segment display tests, then documented the conveyor's sensing and control circuits.
Software
We used object-oriented programming, ROS 2 and pathfinding exercises to build our robotics foundation.
Mechanics
We progressed from individual SolidWorks parts to the physical sorting conveyor.
From design to fabrication.
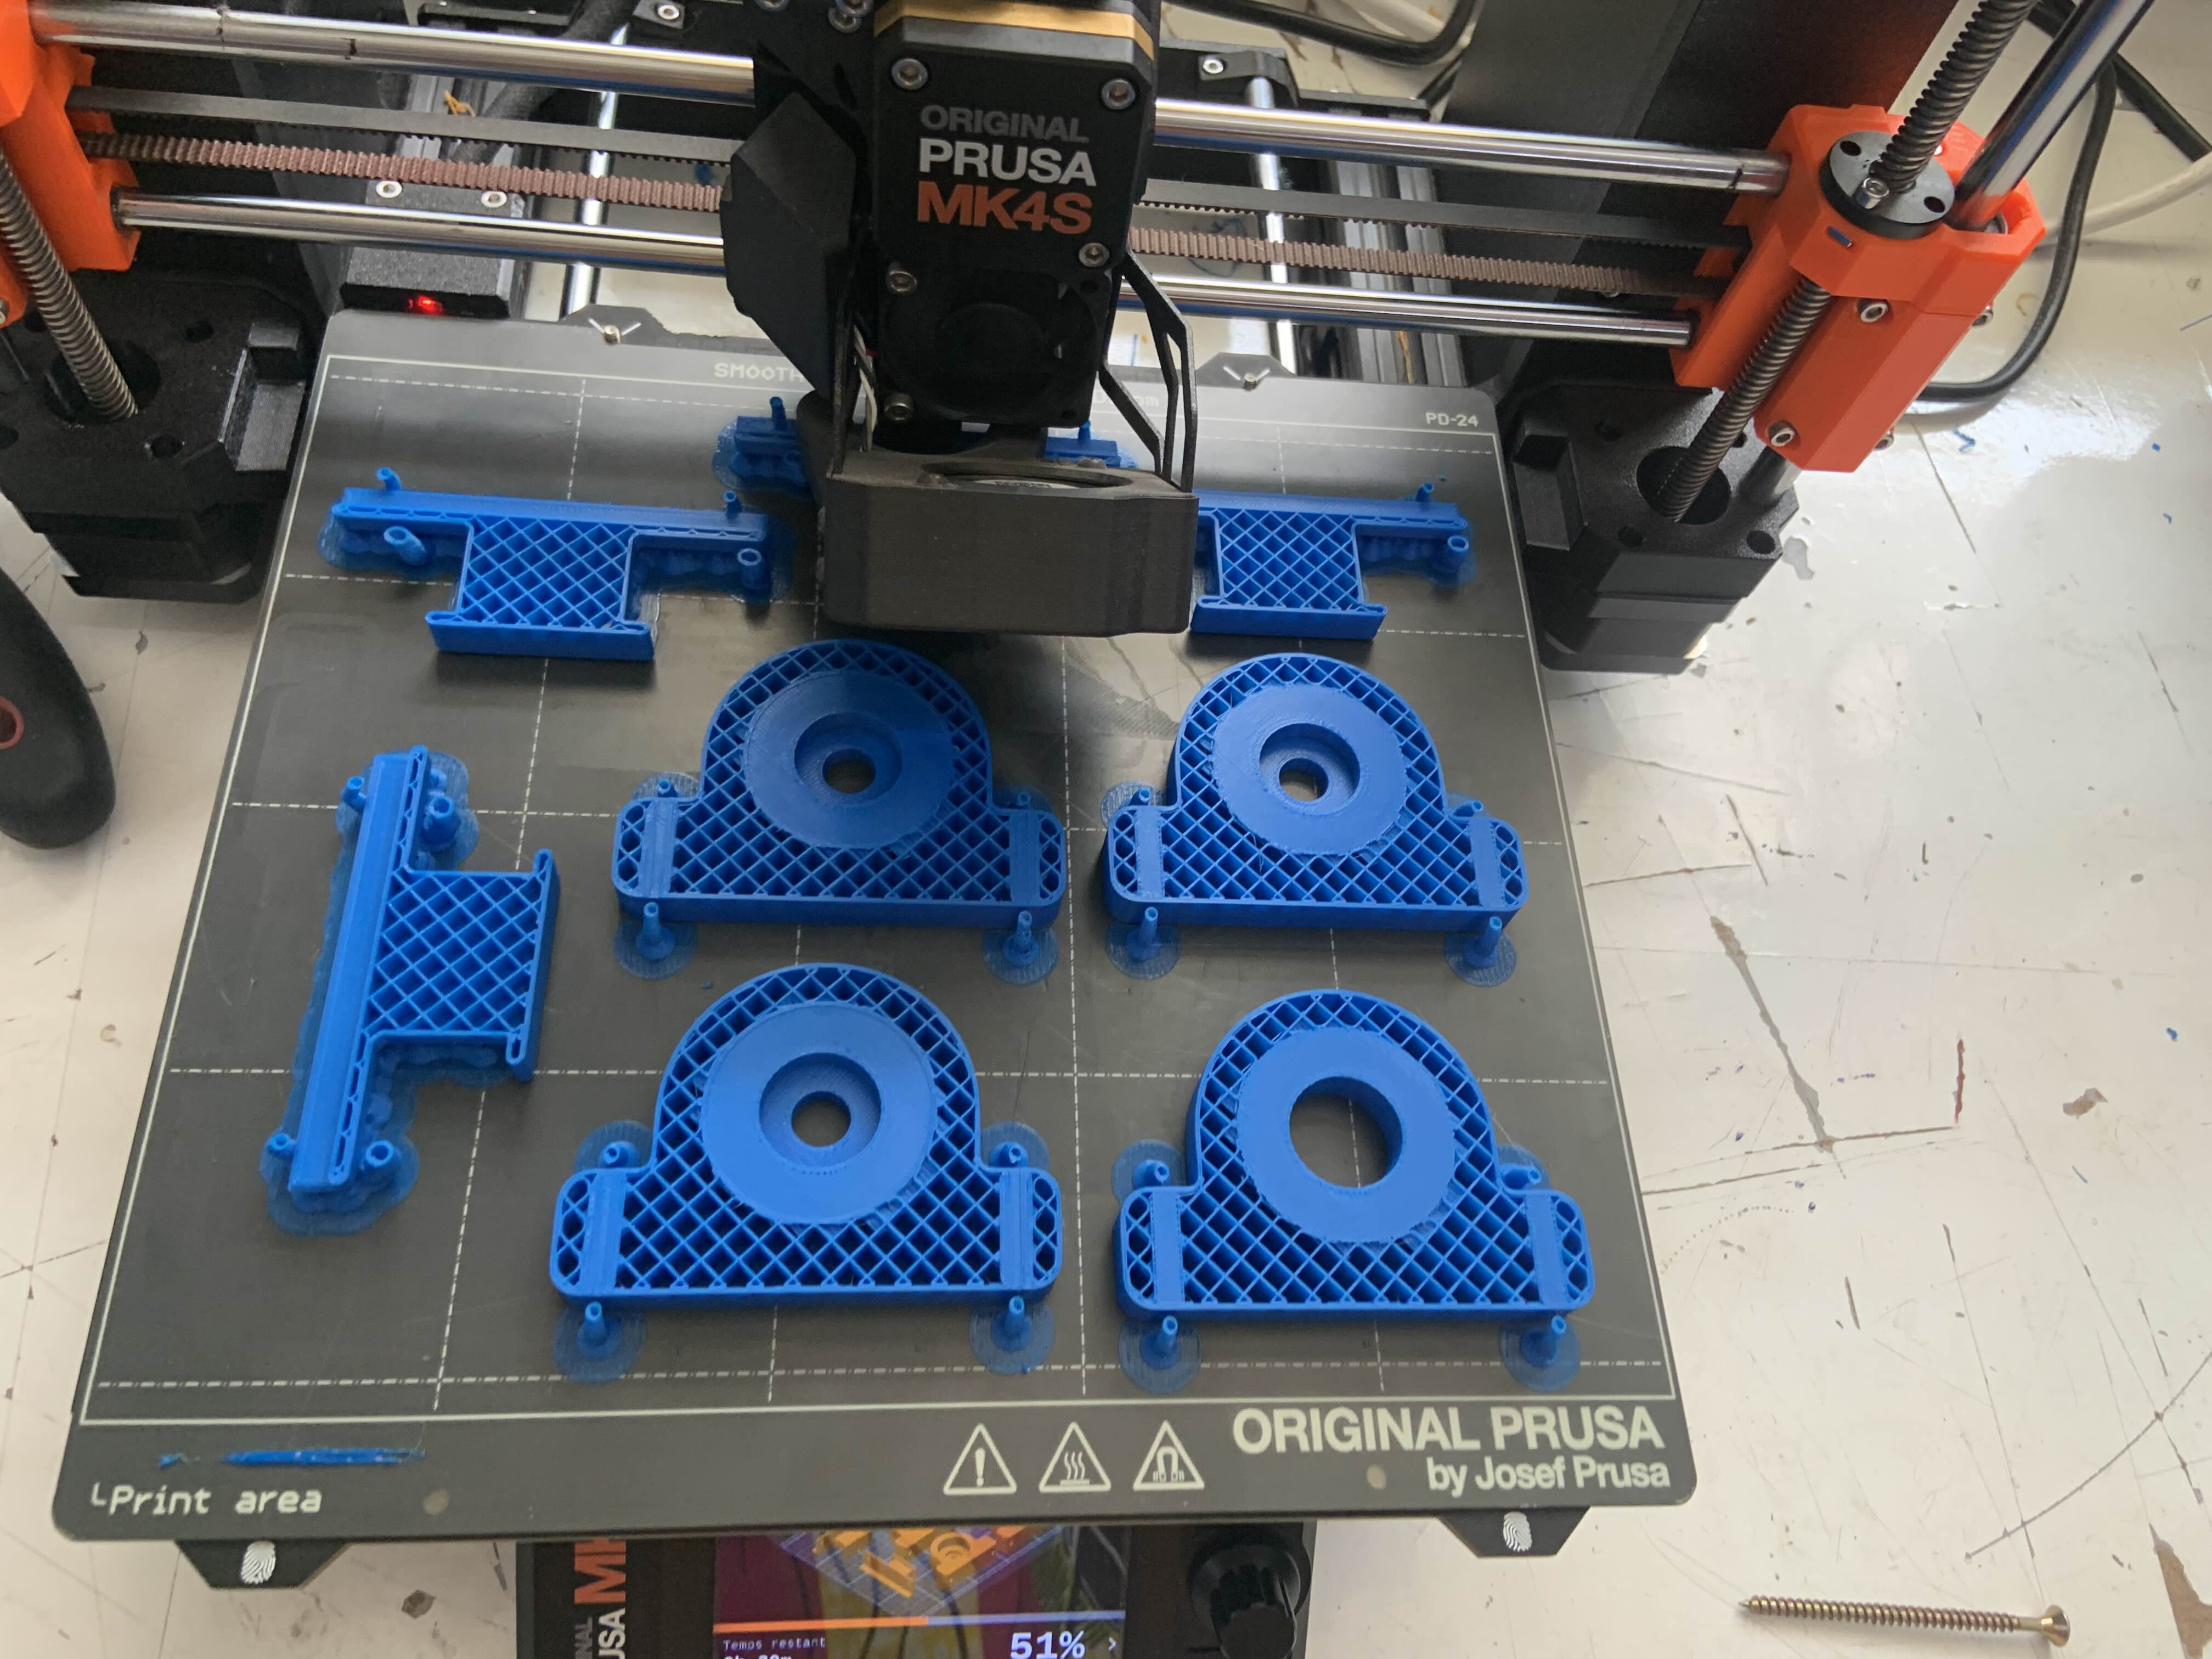
We documented the conveyor's control architecture, its fabricated parts and our progress on a bilingual site. The photo shows components being 3D printed for our mechanical build.